
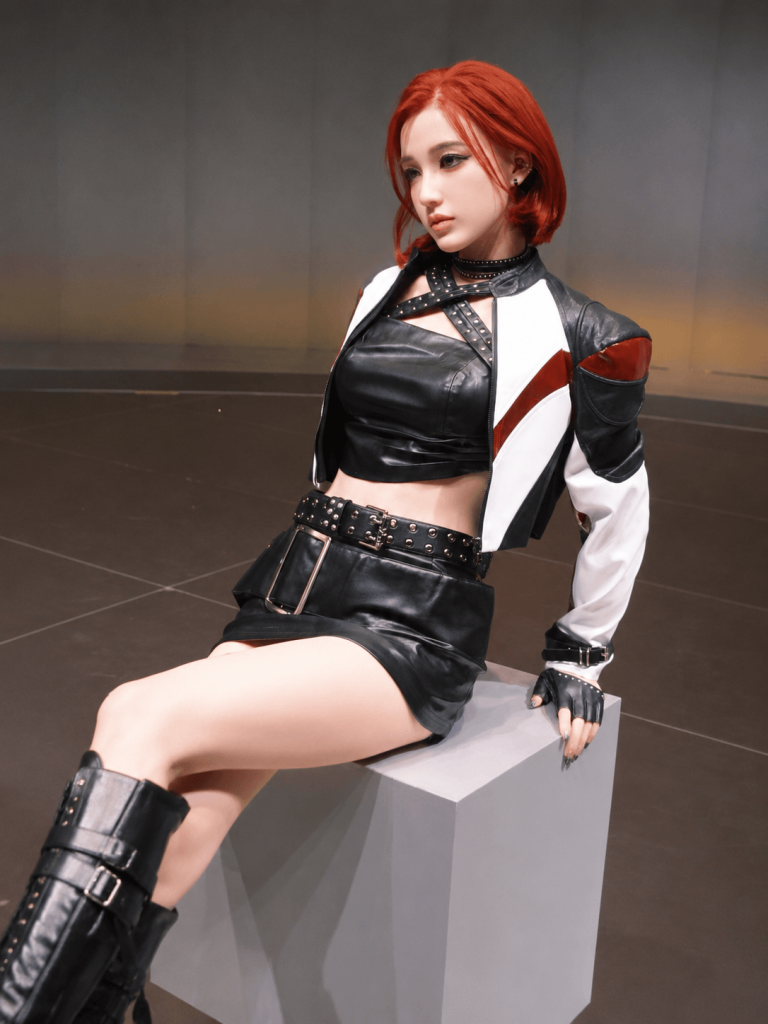
Following the global sensation sparked by its hyper-realistic facial micro-expressions, the leading Chinese bionic developer UWorld has once again sent shockwaves through the premium humanoid collector and tech-geek communities.
In their latest physical demonstrations, engineers showcased a stunning breakthrough: their ultra-lifelike humanoid robot (Hyper-Realistic Humanoid) successfully hand-held and danced with humans, displaying a level of weight-shifting balance and motion fluidity that closely mirrors a professional ballet dancer.
As the leading independent archive tracking high-fidelity androids and companion robotics, the DollArchives team conducted an on-site, hands-on kinematic audit of UWorld’s physical movement mechanics and locomotion architecture. Here is our exclusive technical breakdown.
⚙️ Under the Hood: 88 Degrees of Freedom & Kinematic Mimicry
Achieving human-like gait on a full-scale bipedal humanoid is a monumental task—often far more challenging than programming facial expressions. Traditional humanoids are plagued by mechanical stiffness, wide-stance “duck walks,” or jerky joint transitions. UWorld attempts to bypass these limitations through two core hardware and software developments:
1. An 88-Degree-of-Freedom (DoF) Skeletal Matrix
UWorld is engineered with an impressive 88 independent kinetic degrees of freedom across its entire skeletal framework. Driven by proprietary, high-density multi-axis servo actuators, each joint’s torque profile has been meticulously tuned to mimic human muscular damping. This extensive range of motion is precisely what allows the robot to handle delicate pivots, slides, and the complex weight-shifting required in partner-dancing.
2. 90%+ Human Gait Replication
The developer claims their bio-inspired locomotion algorithms replicate over 90% of a natural human walking gait. Our on-site observation confirms this is not mere marketing hype. The kinetic coordination between the hip, knee, and ankle joints is remarkably soft. When walking alongside the robot or engaging in slow dance movements, the locomotion kinetics flow with an organic continuity rarely seen in commercial-grade humanoids.
🚨 DollArchives Field Review: The Two Major Kinematic Bottlenecks
While UWorld’s physical grace and aesthetic posturing (particularly the highly stylized, elegant adjustments tuned for female models) are artistic triumphs, DollArchives remains committed to providing unbiased transparency. During our hands-on evaluation, we observed two critical technical limitations that prospective overseas buyers must consider:
1. “Facial-Motion Decoupling” During High-Dynamic Movements
We identified a highly noticeable break in immersion during physical locomotion: whenever the robot engages in large-scale bodily movements—such as walking or dancing—its facial expressions revert to a static, somewhat rigid state. In robotics engineering, this is known as a computational resource allocation bottleneck. When the onboard system is heavily taxed with executing real-time bipedal balance algorithms, processing power is prioritized for the physical actuators rather than facial micro-expressions. Until multi-threaded processing can sync organic smiles and shifting gazes simultaneously with physical movement, the illusion of life will remain partially broken during locomotion.
2. Terrain-Adaptive Limitations (Flat Surfaces Only)
It is crucial to note that all stunning motion demos, including our own hands-on testing, took place exclusively on perfectly flat indoor surfaces. Currently, the robot’s hardware architecture lacks advanced terrain-adaptive control algorithms. For overseas buyers asking: “Can it climb stairs?” or “Can it walk on gravel paths?”—the answer is currently no. Without advanced active balance adjustments for rough terrain, any minor trip or stumble risks causing catastrophic mechanical damage and severe tearing to the incredibly expensive, delicate soft silicone skin.
- The Battery Drawback (2 to 4-Hour Limit): Additionally, powering 88 high-torque joint actuators simultaneously drains substantial power. In high-dynamic environments (such as continuous dancing or long-distance walking), the actual battery life is capped at a strict 2 to 4 hours.
🌐 White-Glove Solutions for International Buyers
With domestic waitlists for UWorld stretching out for months, overseas collectors and commercial entities face major hurdles in secure procurement and technical verification. DollArchives leverages its local presence to offer end-to-end, white-glove services:
- On-Site Kinematic Audit & Custom Validation If your commercial deployment or personal collection demands strict verification of specific movements (such as joint damping coefficients, walking stability, or custom choreography coordination), our engineers can visit the domestic factory floor or showroom on your behalf to run custom diagnostic tests. (Note: This custom technical audit requires the client to cover baseline travel allowances and auditing fees).
- Expedited Priority Sourcing (Broker Channel Acceleration) To bypass the paralyzing official waitlists, we tap into our local industry network and authorized domestic procurement channels (VIP broker/scalper services) to secure immediate inventory allocations and fast-track your dispatch window. (Note: This expedited service involves custom resource integration and incurs a localized broker surcharge).
📞 Contact Us to Secure Your Next-Gen Bionic Masterpiece
Whether you require a highly detailed factory technical audit report or want to utilize our priority channel to secure this 90%-human-gait bionic masterwork:
- Official Business WhatsApp: 👉 Click here to Chat with us on WhatsApp
- The Authoritative Database: DollArchives.com